Point-to-Rectangle Collision Avoidance
In trajectory planning, rectangles are commonly used to represent bounding boxes of moving entities such as vehicles and robots. The point-to-rectangle collision avoidance feature enables collision avoidance constraints between a point and a rectangle, ensuring that the point does not enter the area occupied by the rectangle.
Modeling
Below is an example of a point-to-rectangle collision avoidance inequality constraint:
point2rect_ineq = point_to_rectangle_inequality(
    px, py,
    x, y, phi, width, length,
    distance_to_avoid
)
prob.inequality(point2rect_ineq)
The parameters of the point_to_rectangle_inequality interface are as follows:
px,py: Coordinates of the point that needs collision avoidancex,y,phi: Center coordinates and orientation of the rectangle (counterclockwise is positive)width,length: Width and length of the rectangledistance_to_avoid: Avoidance distance
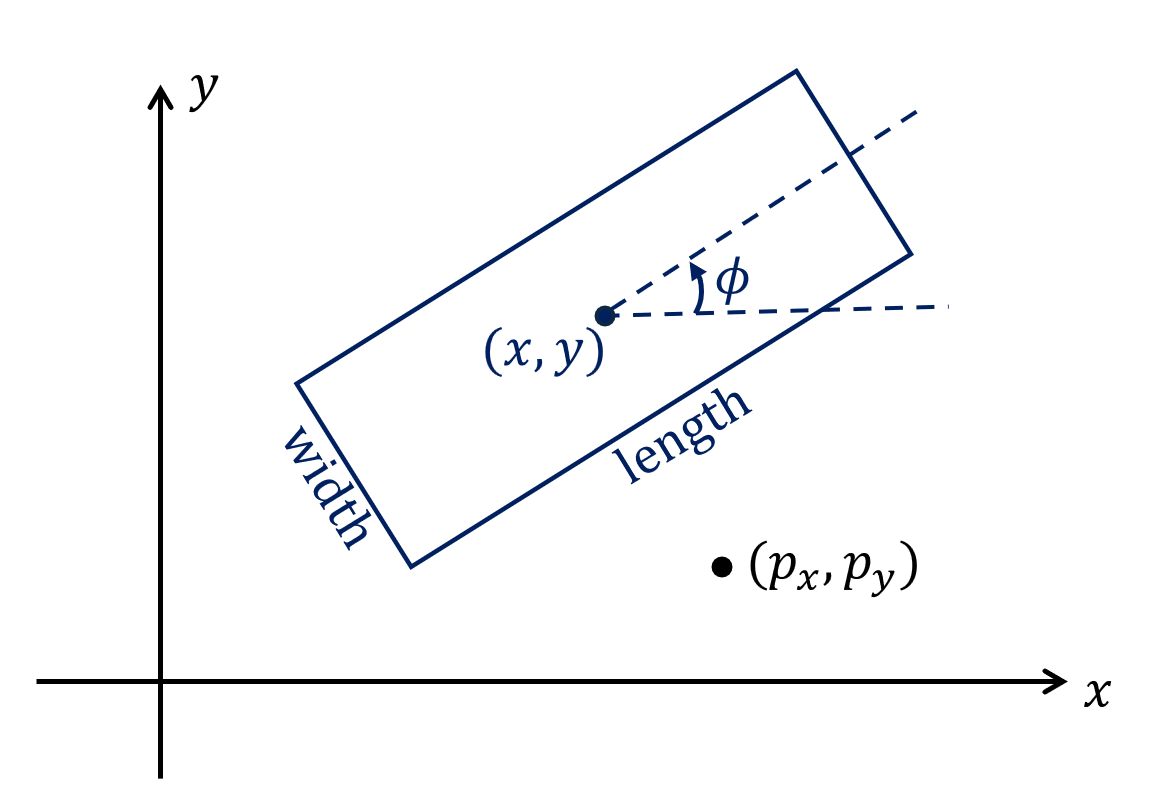
All parameters of the point_to_rectangle_inequality interface (px, py, x, y, phi, width, length, distance_to_avoid) can be constants, expressions in terms of parameter , or expressions in terms of optimization variable .
Results
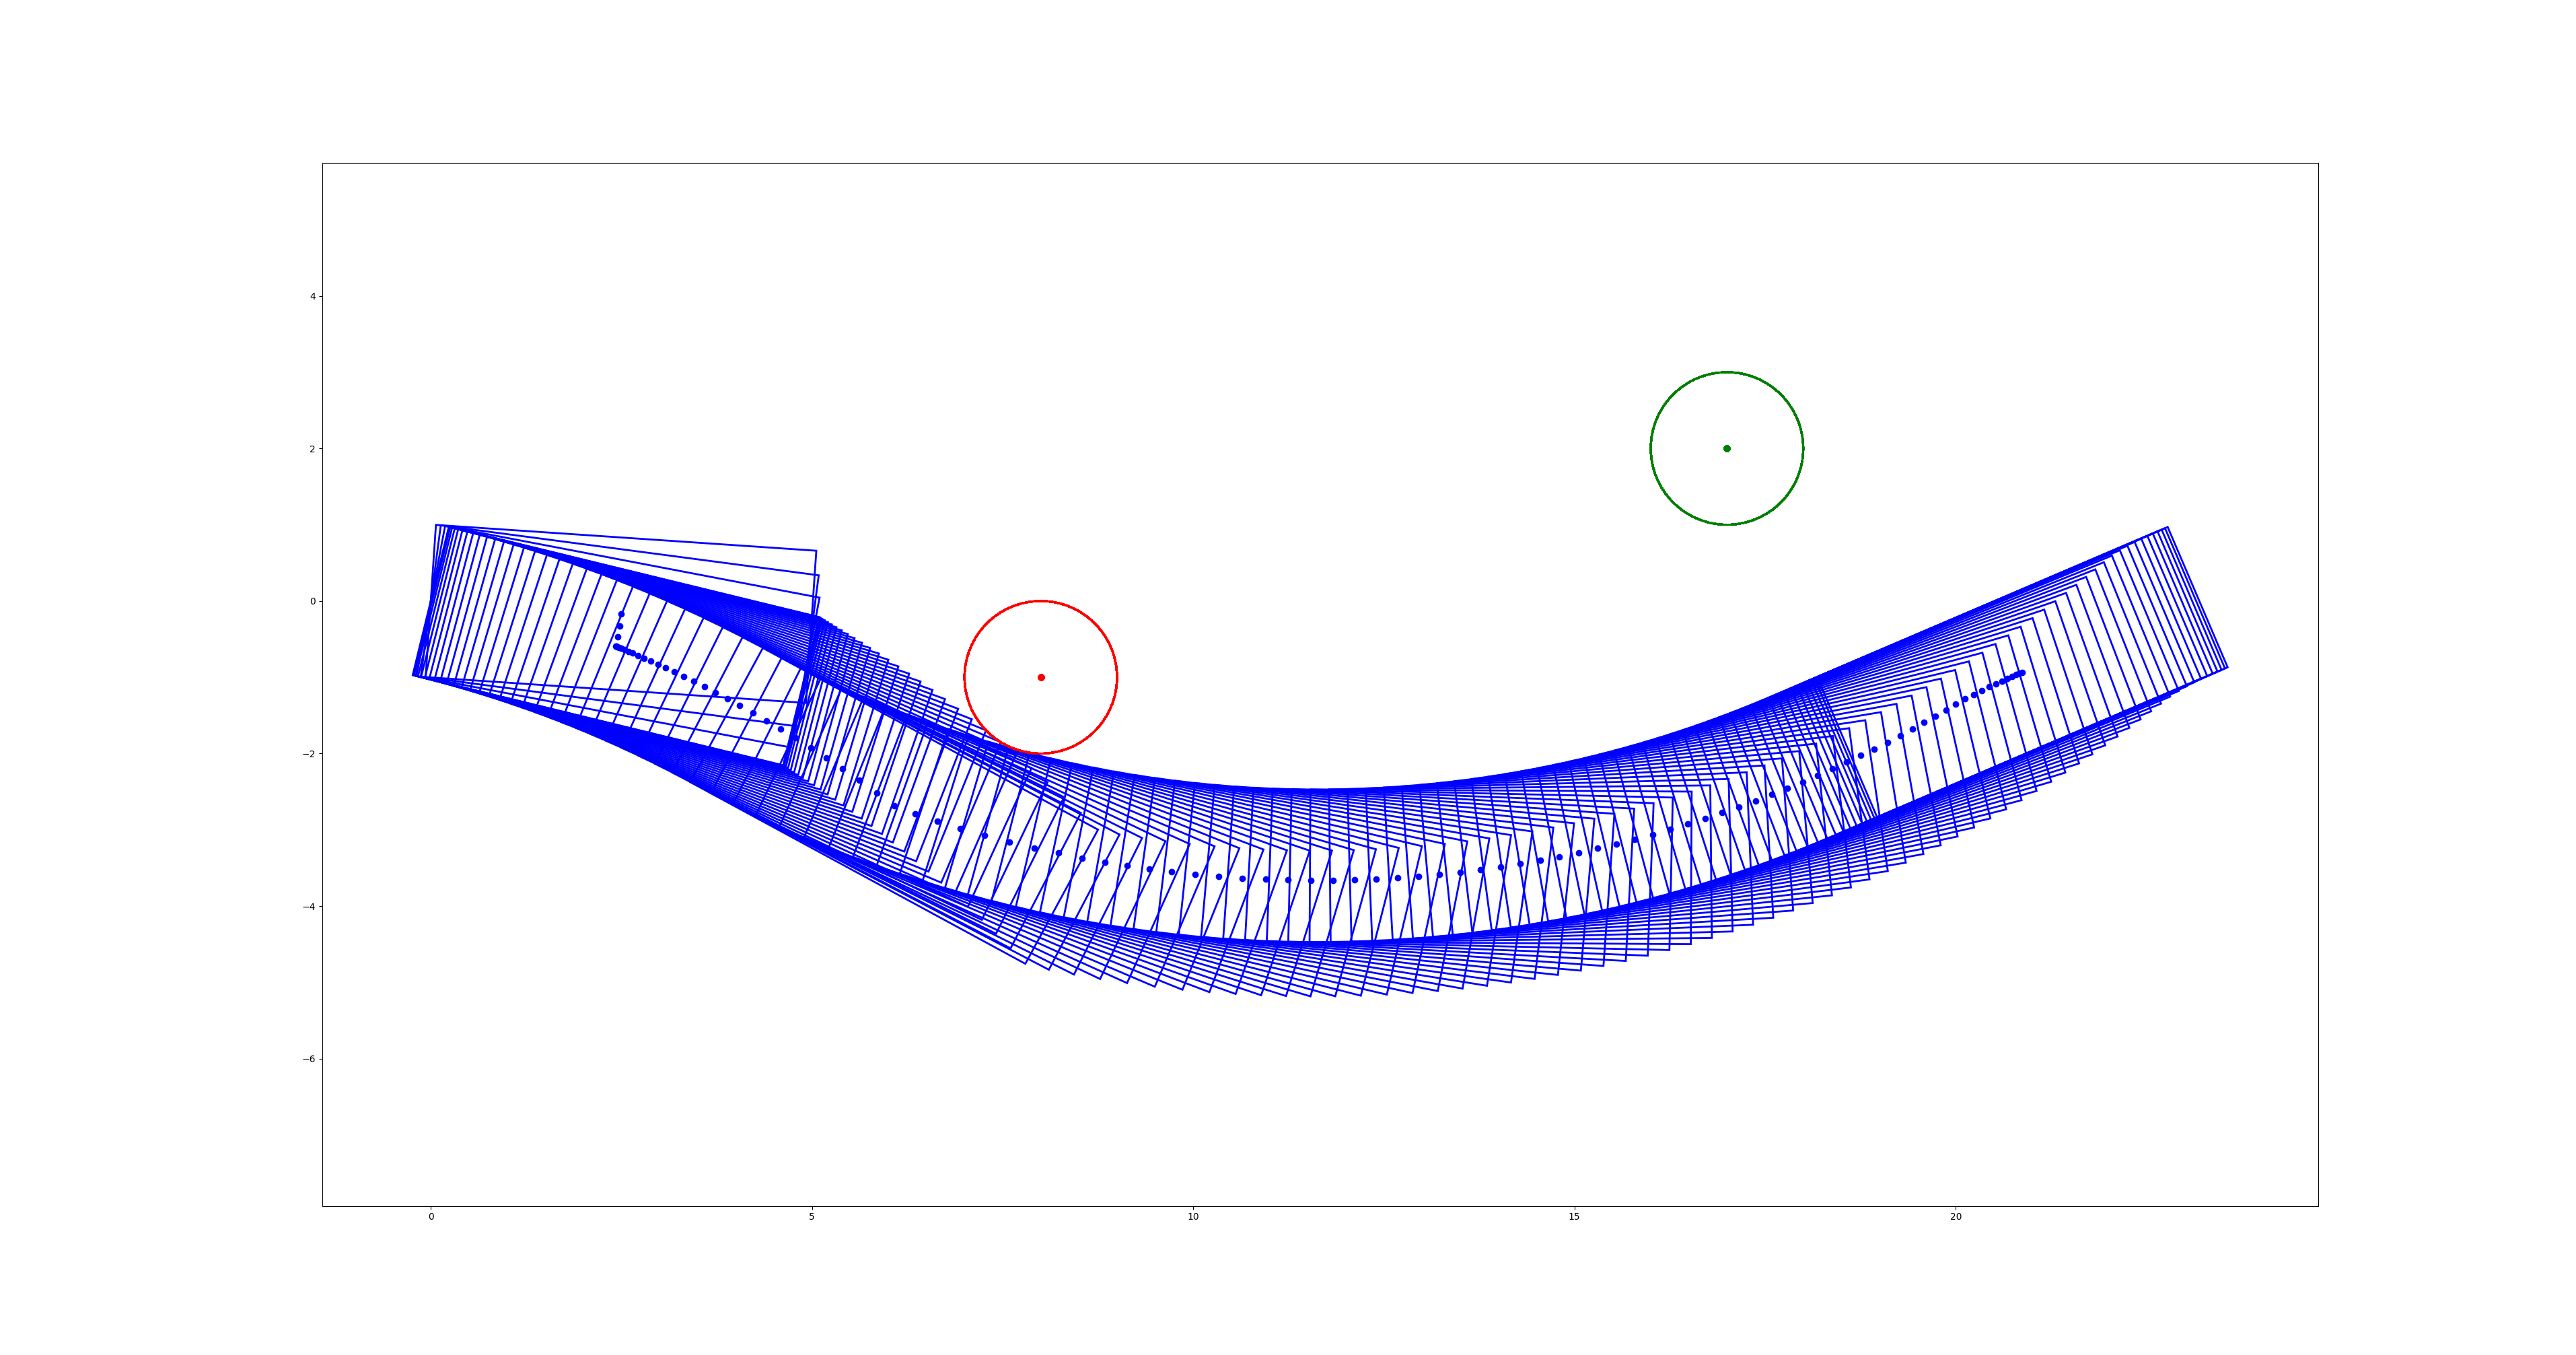
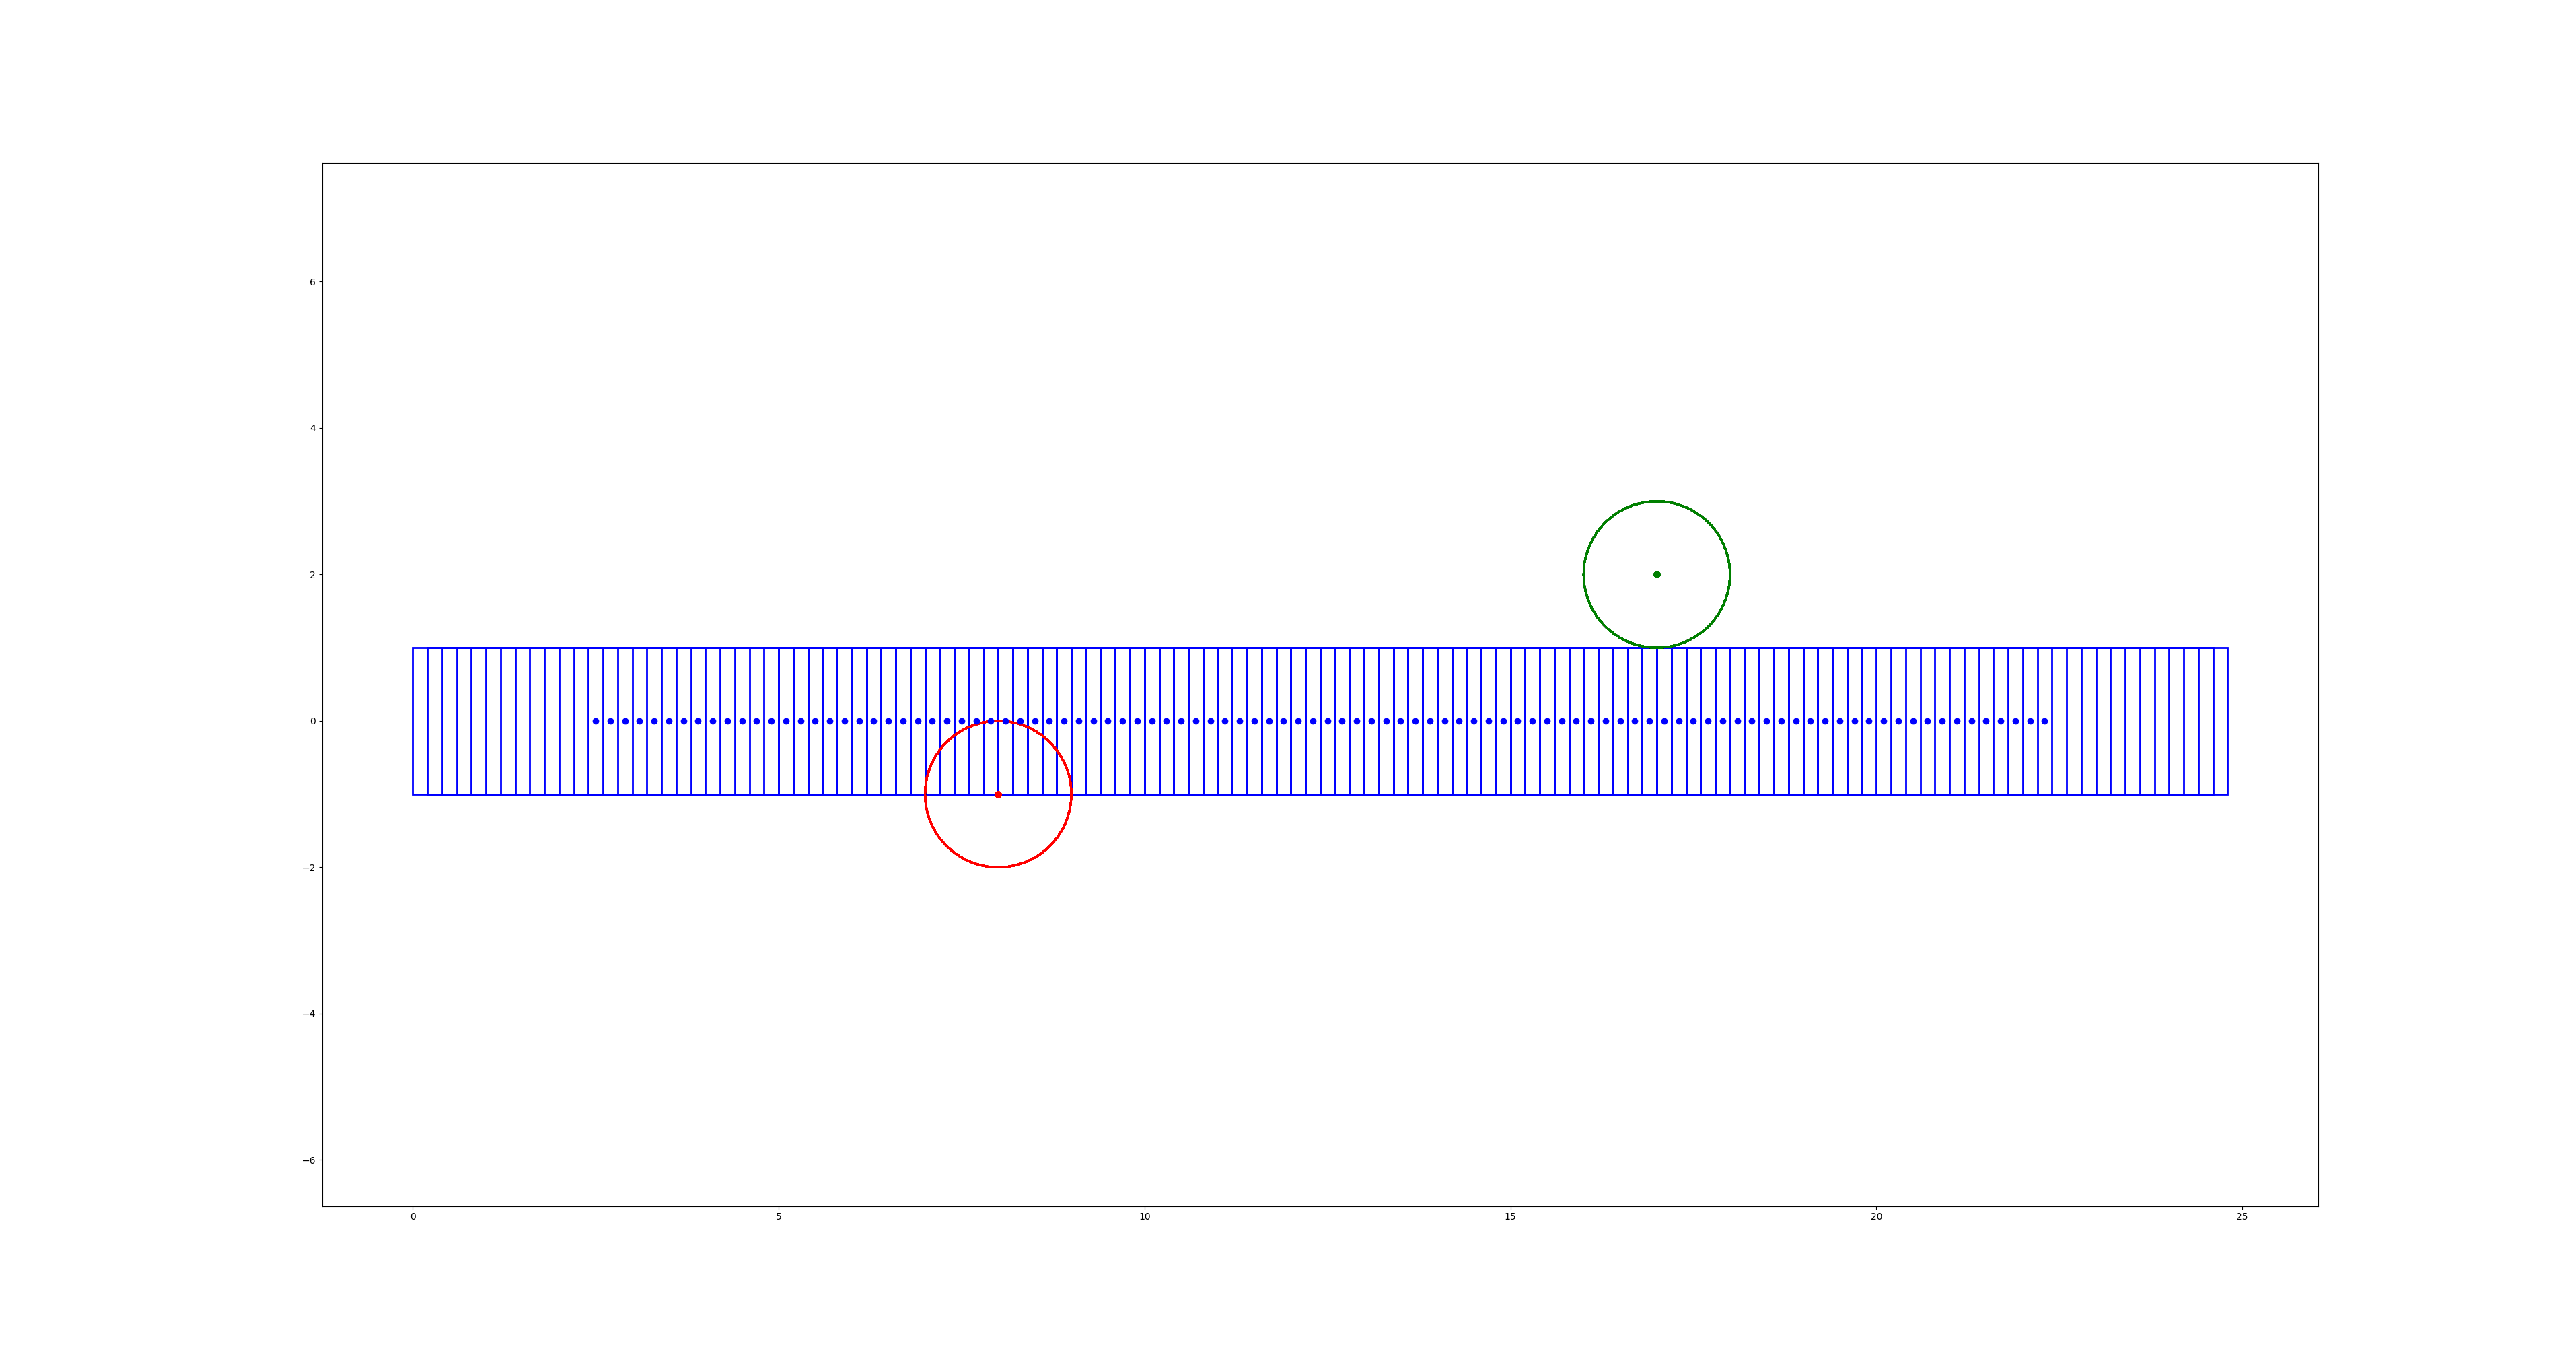
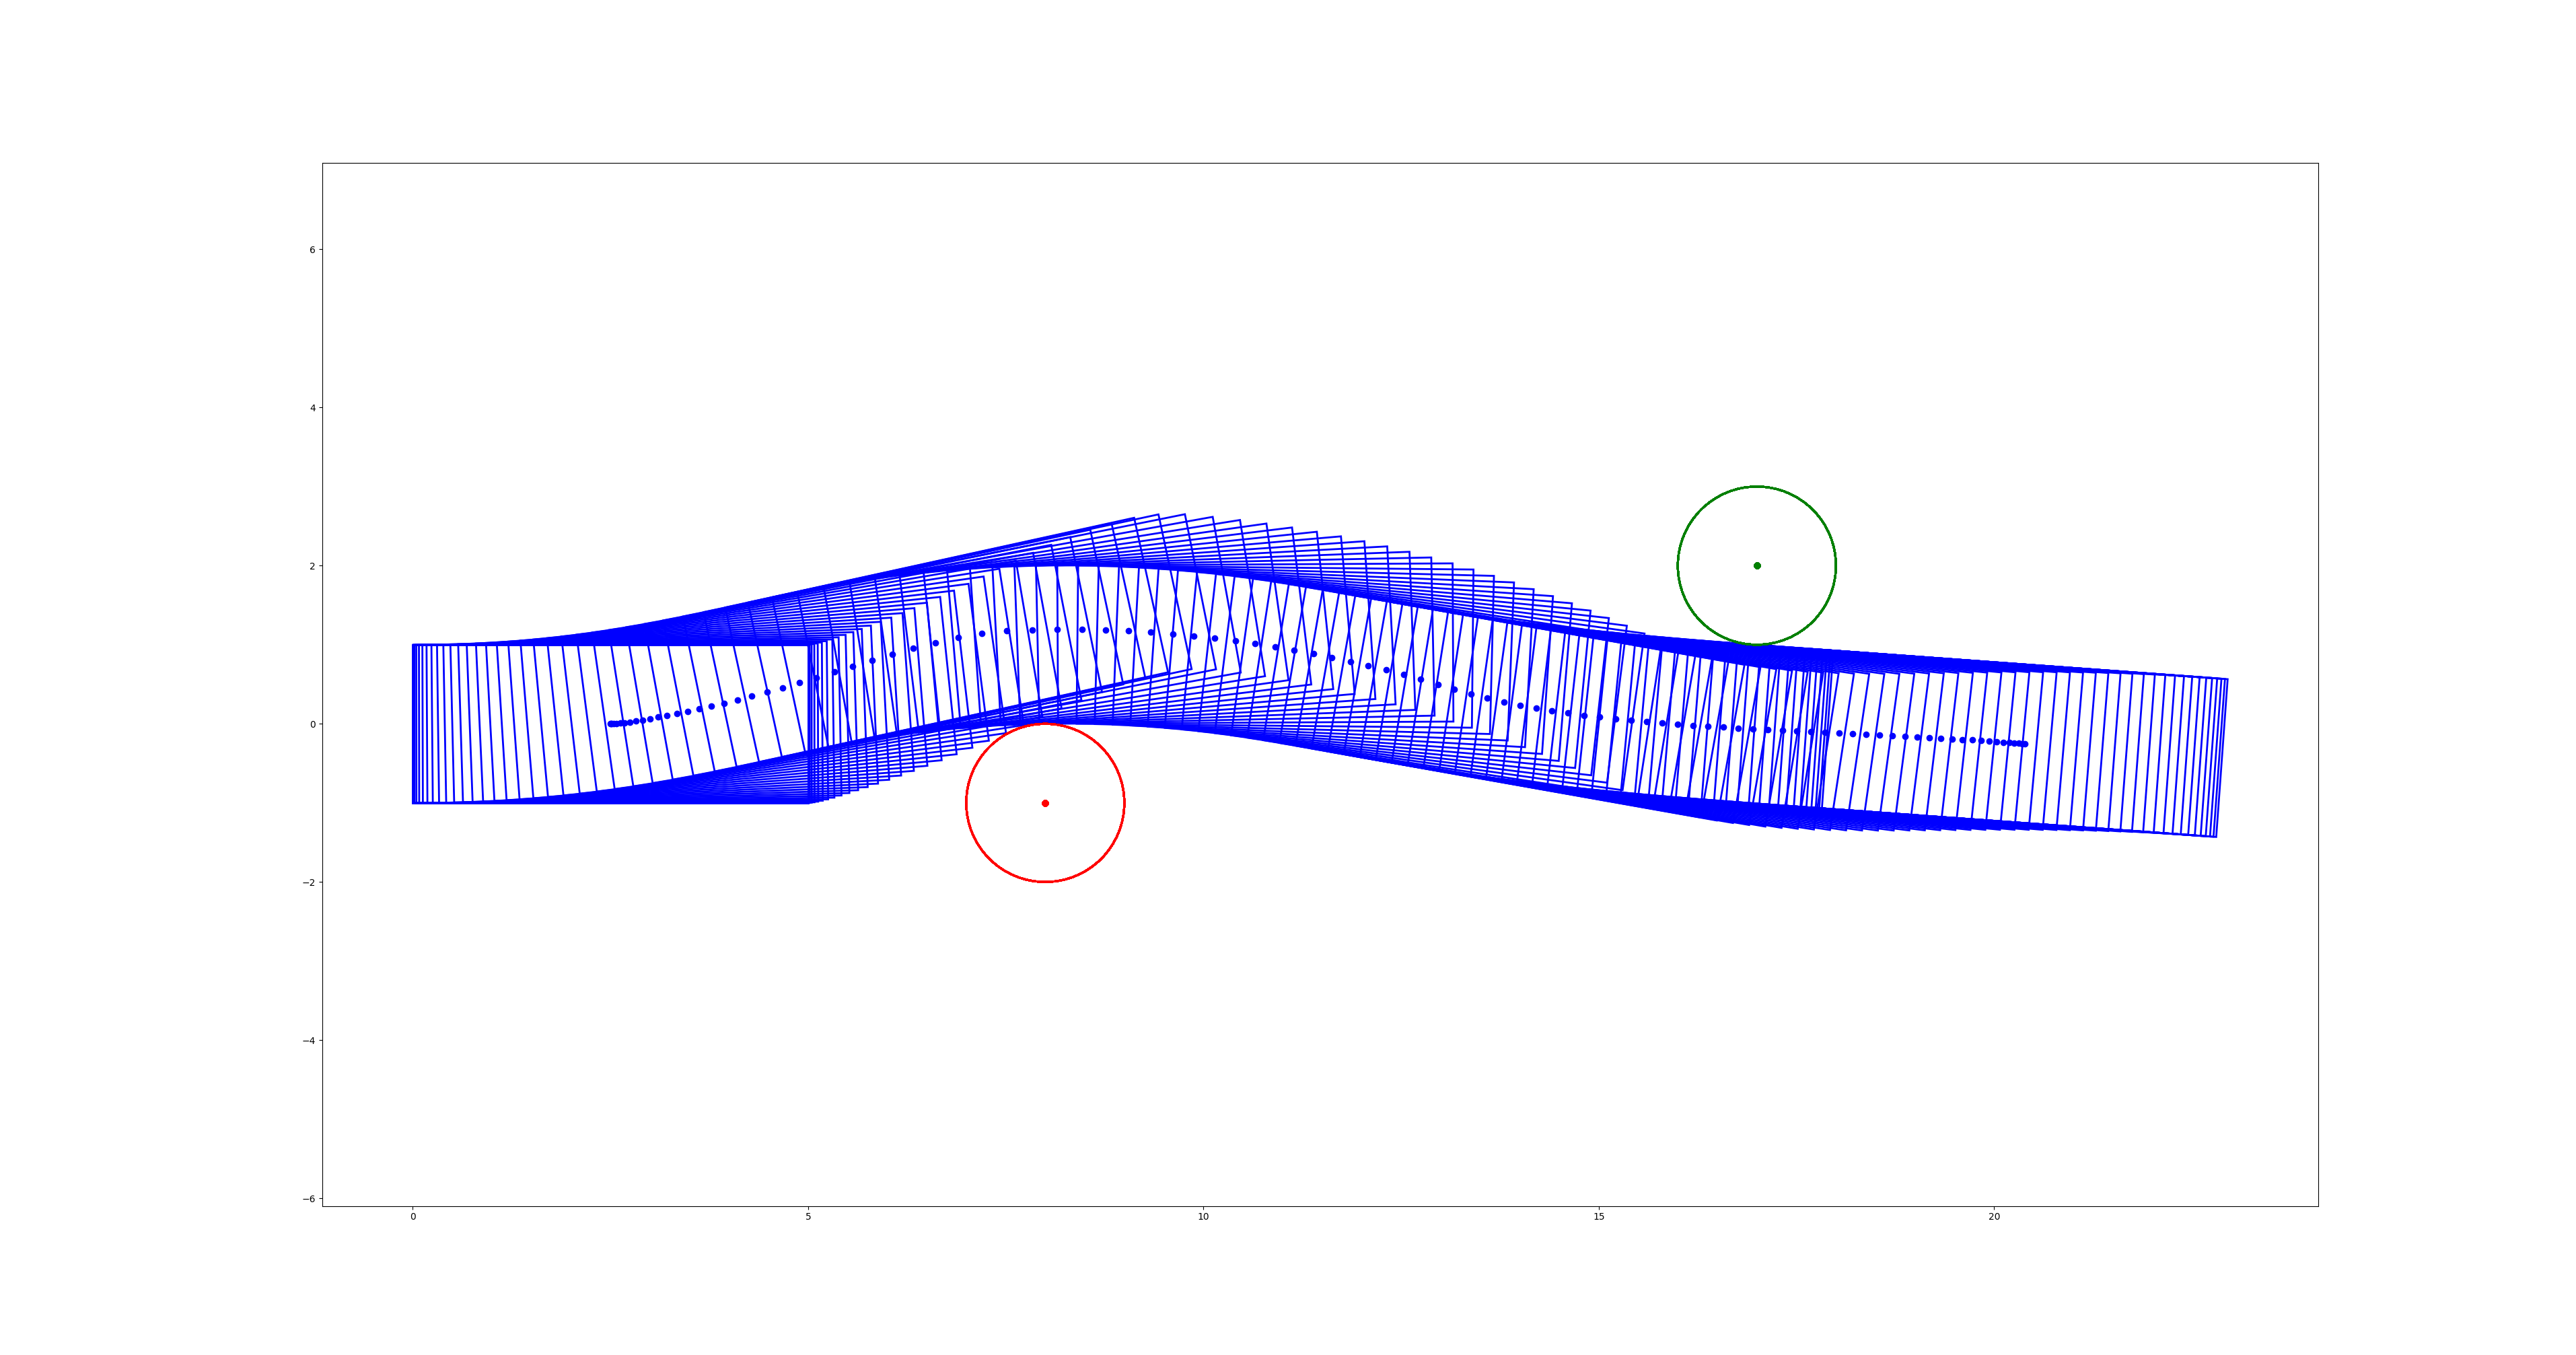
Below is the problem setup for vehicle collision avoidance trajectory planning using the point-to-rectangle collision avoidance feature:
- The vehicle starts at pose 0, with the goal of tracking the reference line along the x-axis (horizontal axis) while avoiding two pedestrians (described as points)
- The vehicle's optimized trajectory consists of 100 stages. At each stage, i.e., at each time point, the vehicle avoids both points with an avoidance distance of 1.0 m
Note that the positions of pedestrians can differ at different time points, meaning dynamic collision avoidance problems can be handled.
Below are trajectory planning results under different initial guesses:
- Initial guess above
- Initial guess in the middle
- Initial guess below
Initial guess:
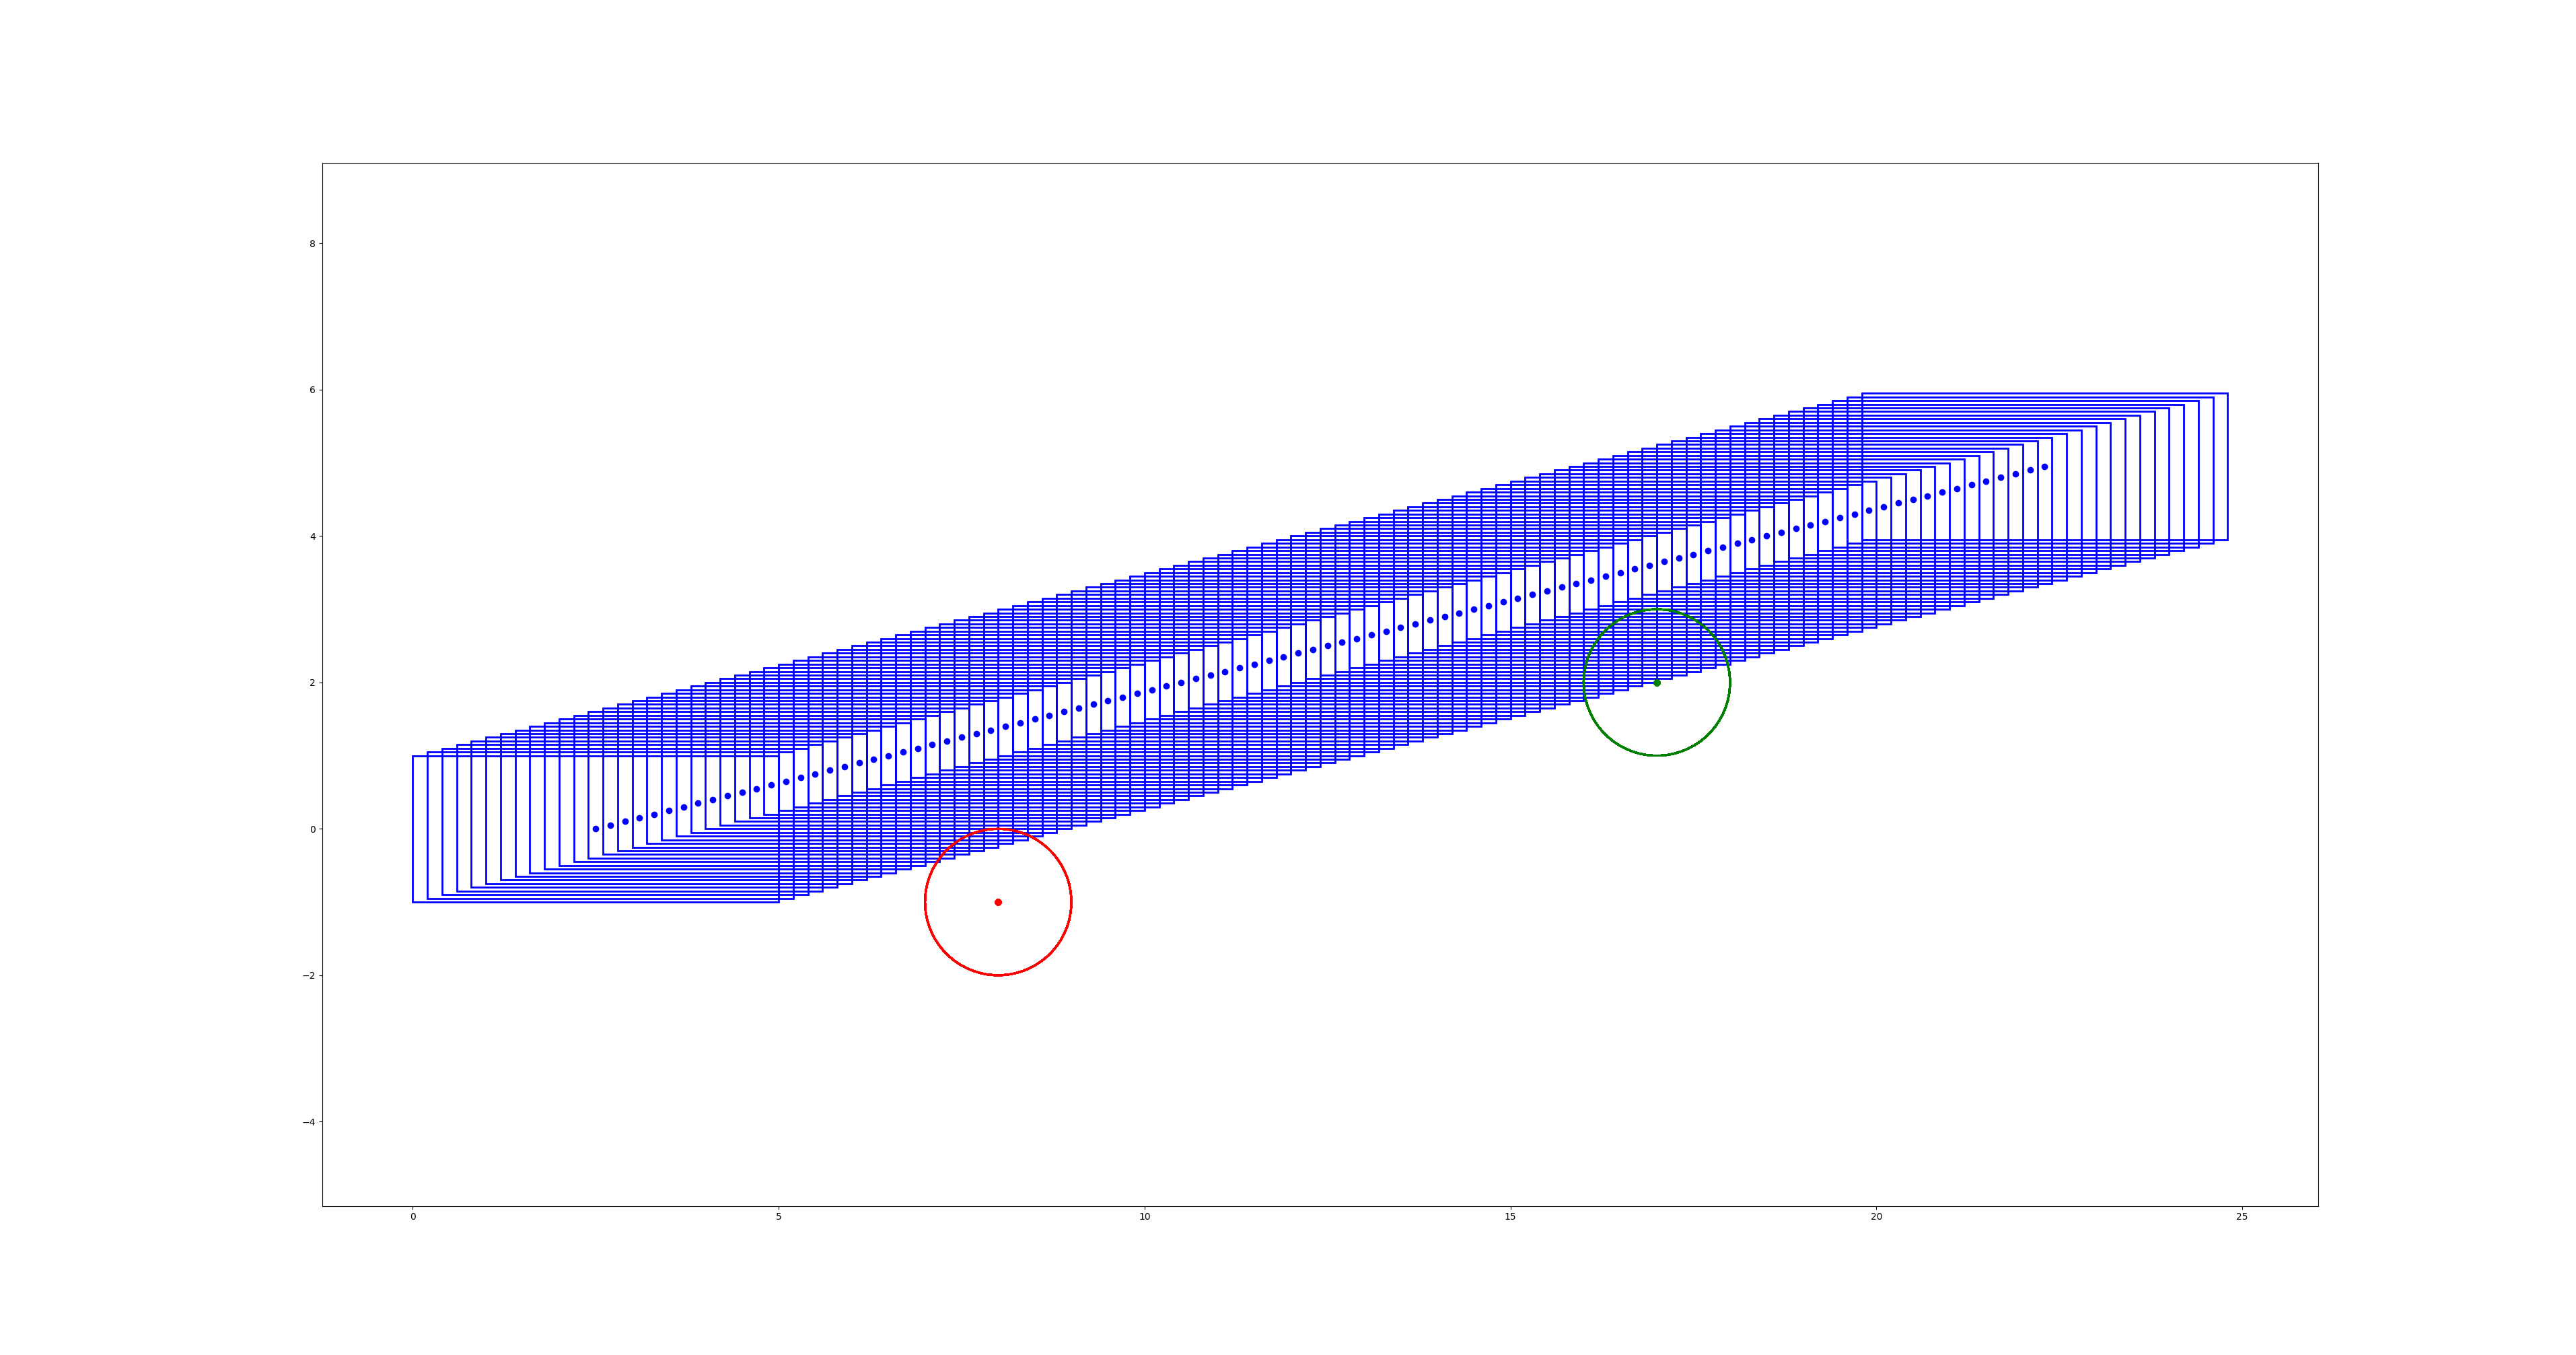 Optimal trajectory:
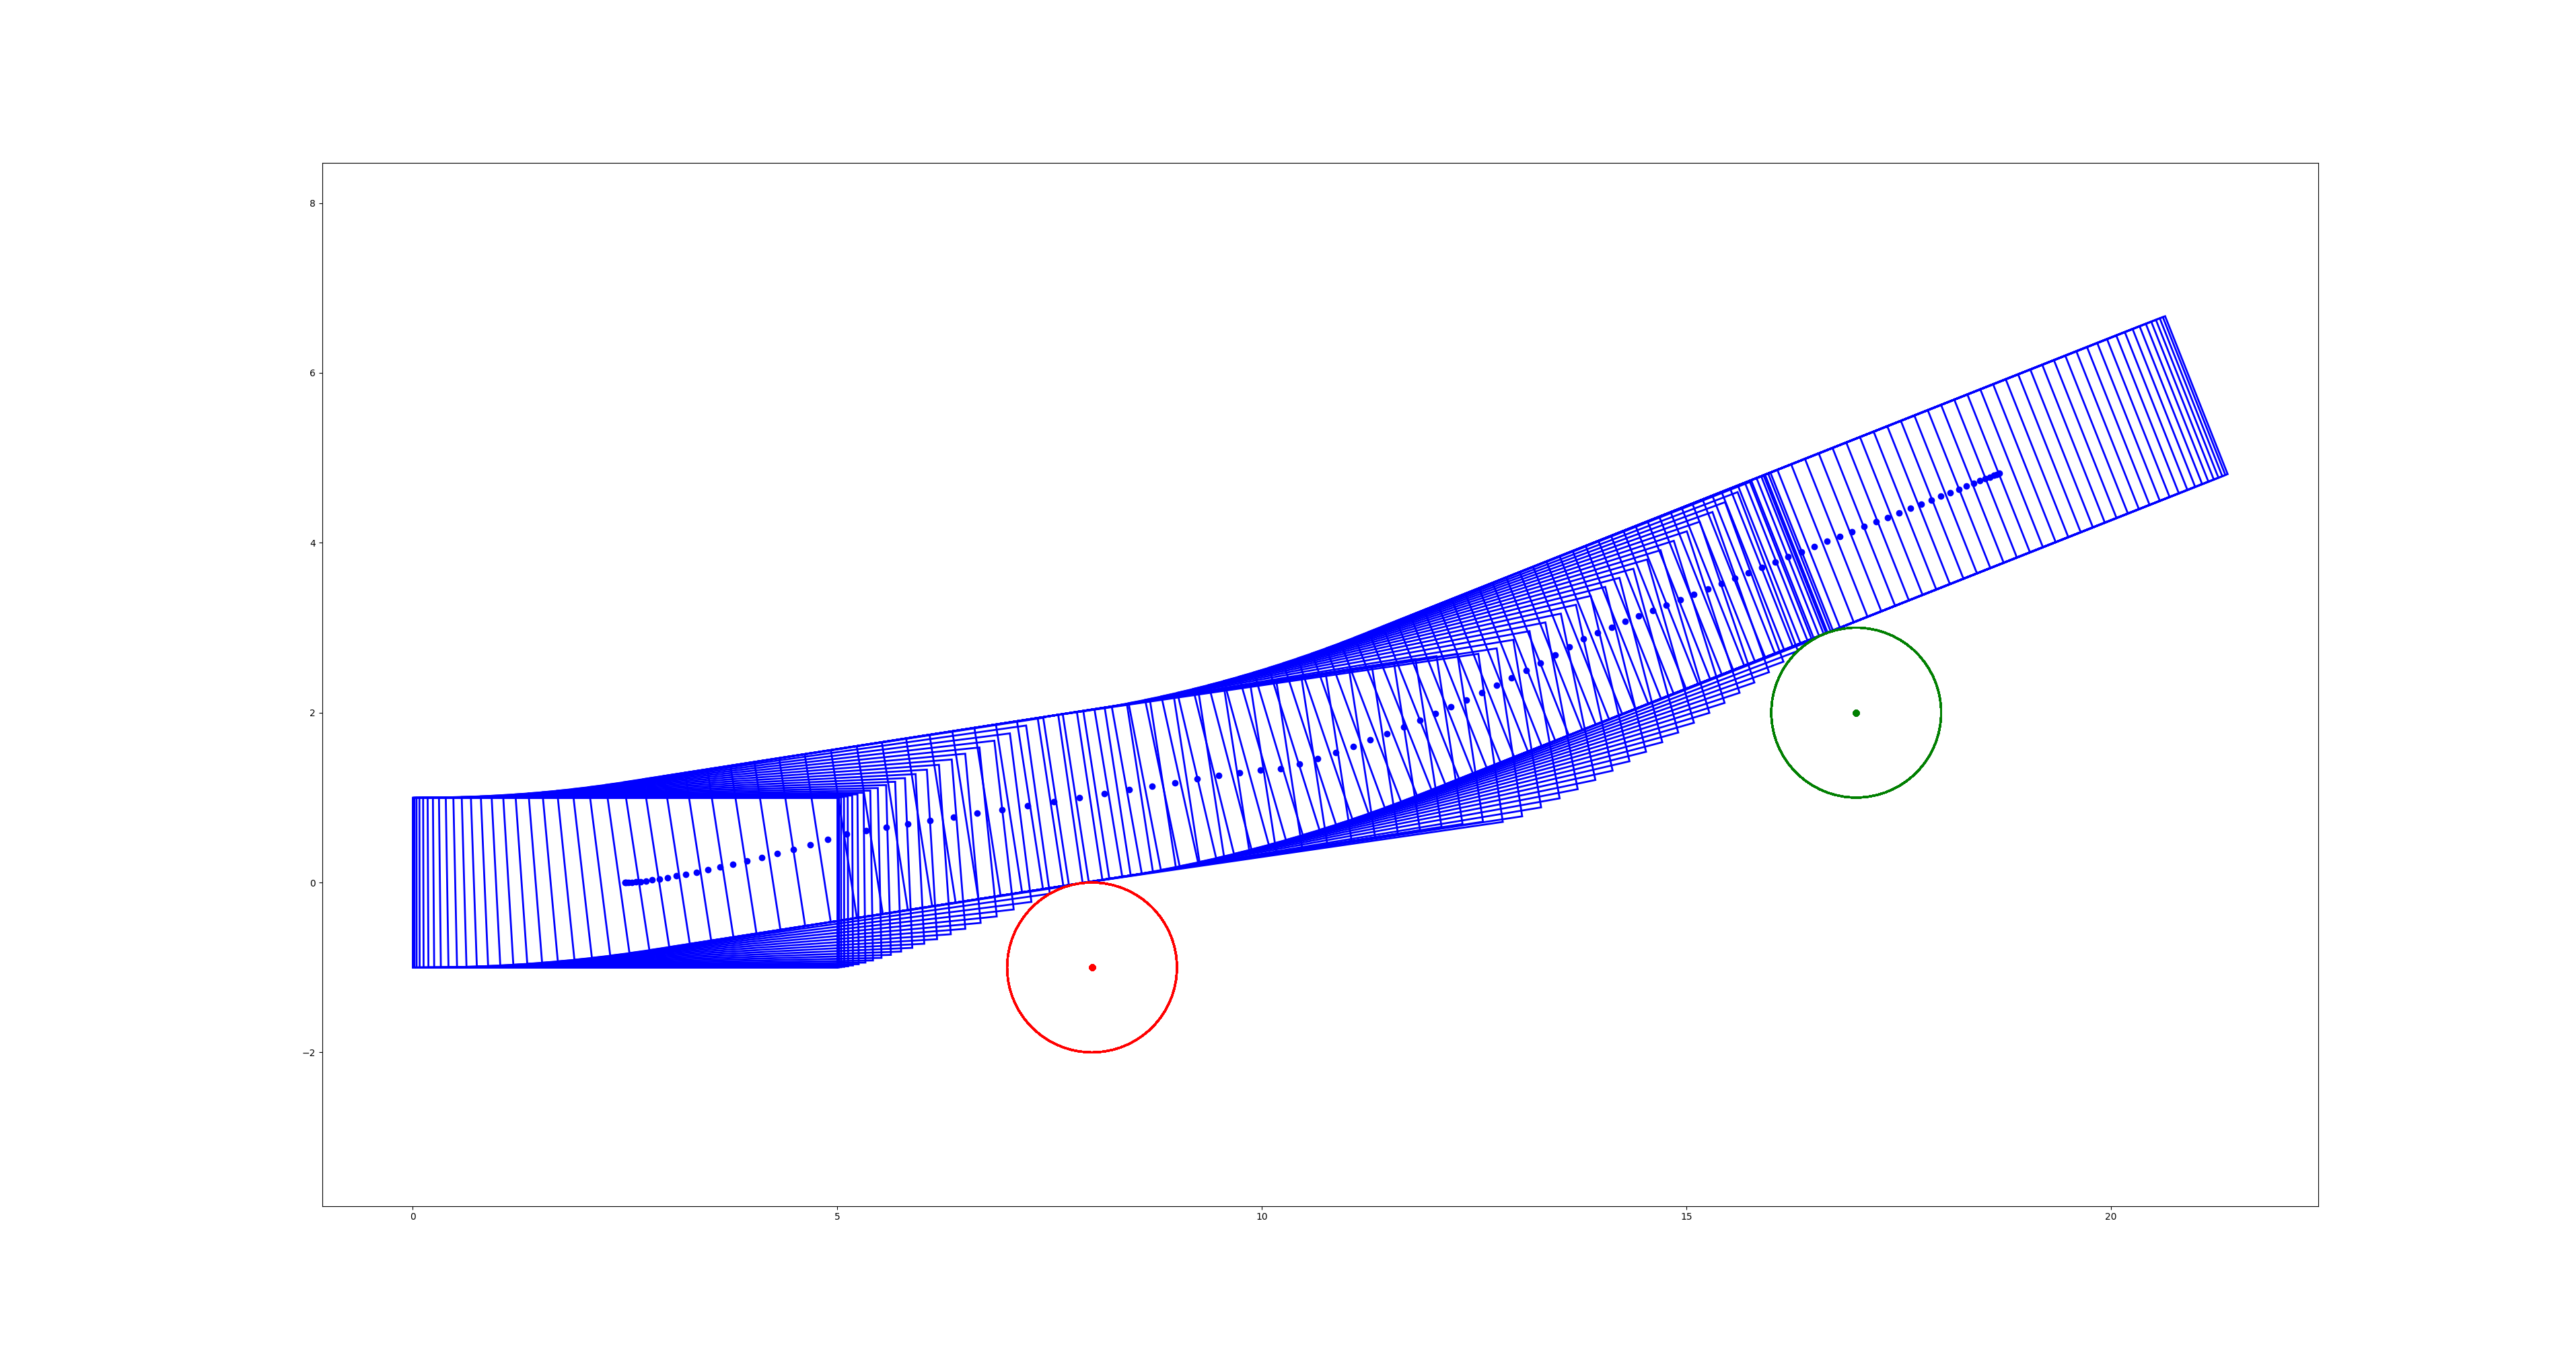
Initial guess:
 Optimal trajectory:
Initial guess:
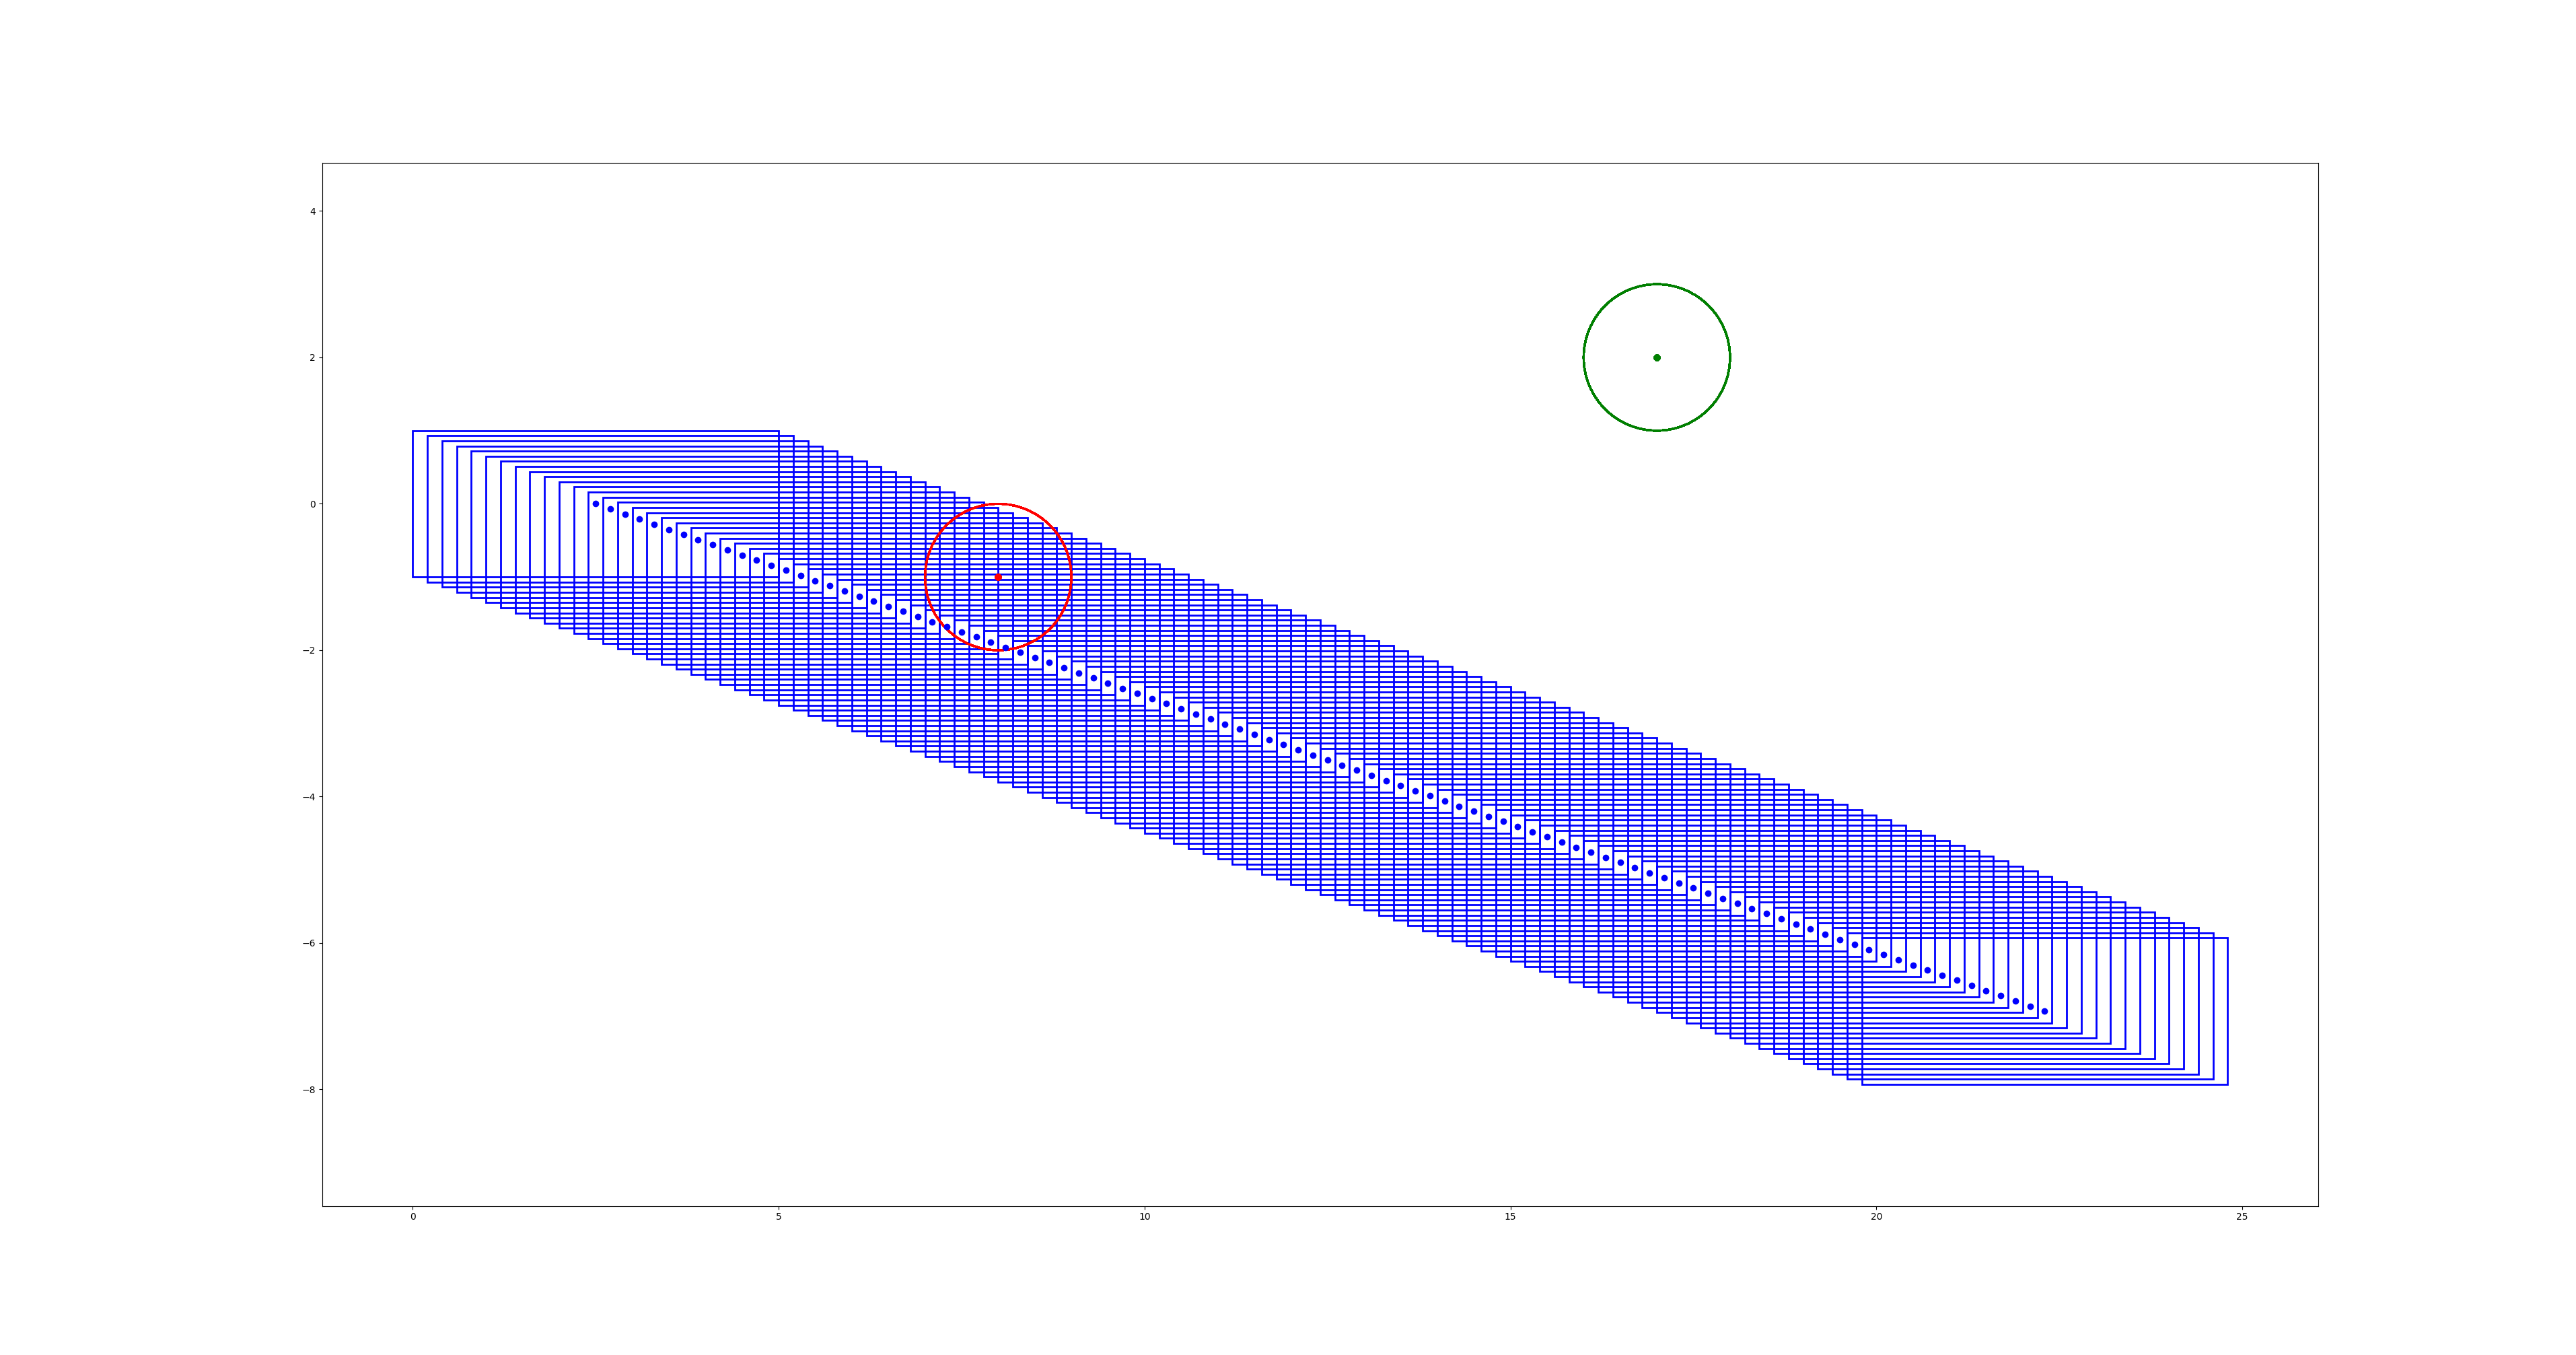 Optimal trajectory (limited by maximum steering angle constraint, the solver returns
solve_status = 3 infeasibility flag with the minimum constraint violation solution):